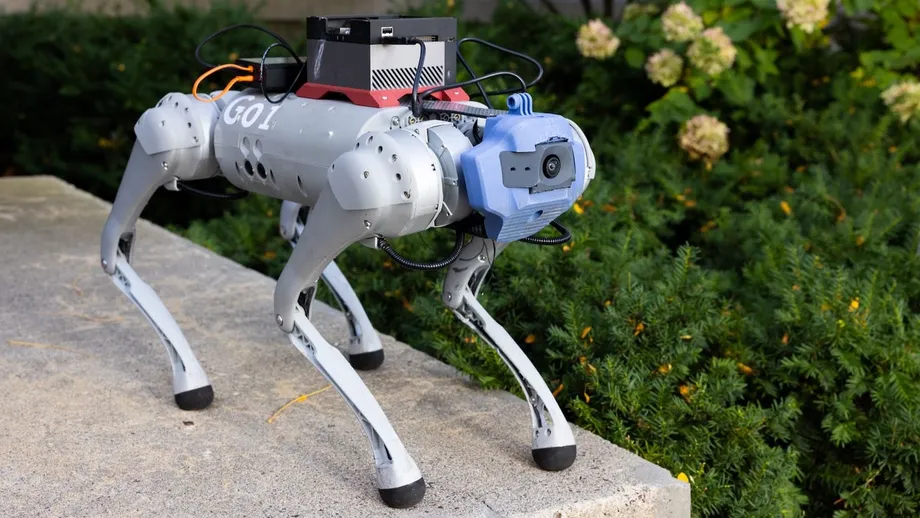
Three robots take on the first day of university
Robotic dogs carried luggage, served drinks and danced for arriving students at Zhejiang University's Zijingang campus, turning move in day into a demonstration of machines doing useful work alongside human volunteers. Three models from DEEP Robotics divided the tasks: Lite3 entertained families, X30 hauled heavy suitcases, and Lynx M20 combined wheels and legs to travel across flat ground and climb steps.
Contents
- Three robots take on the first day of university
- Lite3 turns balance into a welcome
- X30 carries the weight, while Lynx M20 changes gear
- How a robot keeps its footing
- A lighter arrival for students and parents
- University research reaches campus paths and an ancient pagoda
- Other campuses introduce digital and physical helpers
- Zhejiang's robots are also chasing speed
- The developments leading to the September welcome
- Useful assistance still needs supervision
- From a welcome event to practical campus trials
- Highlights
The X30 machines were described as capable of carrying about 85 kilograms of luggage each. They moved over stairs, uneven stone paths and curb cuts, places where an ordinary trolley can be difficult to use. Lite3 robots performed spins, jumps and front flips, while their balance also allowed them to carry trays and serve drinks without spilling.
Lynx M20 offered a different approach. It rolled quickly along smooth surfaces like a small cart, then used its legs for stairs and slopes. Students watched it cross speed bumps and climb steps after a brief rain while maintaining balance on wet ground.
Campus staff presented the robots as practical assistance during a busy arrival day and an introduction to the university's culture of innovation. Families stopped for photographs, volunteers received help with heavy bags, and new students encountered technology connected to the university's own research community.
The welcome brought together several strands of Zhejiang's robotics work: machines that entertain, machines that carry weight, and research projects pursuing faster running. For students arriving with suitcases, however, the immediate benefit was straightforward. A difficult journey from the campus entrance to accommodation became less physically demanding.
Lite3 turns balance into a welcome
DEEP Robotics gave each model a distinct role so the event could combine useful assistance with a lively greeting. The machines shared agile movement on four legs, precise control and steady navigation in crowded spaces, but their different designs suited different jobs.
Lite3 acted as the ice breaker. Its dances and acrobatic movements drew circles of watching families, raised phones and smiles. The same ability to stay balanced supported the quieter task of carrying a tray of drinks.
Light frames, joint modules capable of producing strong turning force, and motion control software made these movements possible. Engineers describe that turning force as torque. A joint needs enough torque to push a leg against the ground, support the robot's body or catch its weight after a jump.
Lite3's control software planned where each foot should land and when each step should happen. It also kept the machine's weight centered. Those adjustments helped the robot cross small gaps or turn smoothly toward people, as well as perform the movements that made it a popular attraction.
X30 carries the weight, while Lynx M20 changes gear
X30 took on the heavier work. Its stated luggage capacity of about 85 kilograms represented a substantial load for human helpers, and volunteers watched a robot take a suitcase that would otherwise have required two people on a staircase.
The machines used multiple sensors together to detect obstacles and adjust their route. Cameras, sensors that measure depth, and instruments that track motion supplied different pieces of information. Combining those readings helped an X30 respond to a rolling suitcase in its path, shift a step to the side and continue without bumping into people.
Lynx M20 was suited to courier trips between dormitories and checkpoints. Wheels provided speed on flat ground, while walking supplied traction on stairs and slopes. A campus with ramps, paving stones, speed bumps and steps gave the hybrid design several kinds of surface to handle within a single journey.
Wheels can also reduce energy use on smooth floors. Legs extend the range of places a robot can reach, including steps, gravel and puddles. Lynx M20's control system had to manage traction and decide when to switch modes, using information about the surface, slope and planned route.
How a robot keeps its footing
A robotic dog moves through a repeating cycle of sensing, planning and acting. Cameras and depth sensors map what lies ahead. Inertial instruments track its own movement, including whether it is tilting forward or slowing on a slope.
Engineers call the process of combining these signals multi sensor fusion. In plain language, the robot puts several views of the same situation together so it can make a more useful picture of its surroundings. That picture allows it to recognize a curb, a suitcase or a person's leg and plan a route through a crowd.
Motion control then turns the route into individual movements. Software decides which legs should remain on the ground, which should swing forward and how fast the body should travel. Strong joints provide the force needed to push off, land or hold a tray level during a turn.
The system continually shifts foot placement by a few centimeters when the ground is slippery or uneven. Small gaps and bumps require changes in step height and timing. These adjustments happen many times per second, helping explain why an entertaining dance and careful drink service can depend on the same underlying engineering.
Lynx M20 adds another decision to that cycle: whether rolling or walking best suits the next stretch of ground. Its combination of wheels and legs gives it speed where the route is smooth and stability where it becomes more difficult.
A lighter arrival for students and parents
Families reacted quickly to the robots. Parents paused for photographs, students watched the demonstrations, and volunteers smiled as machines took over demanding lifting tasks. The robots attracted attention while also helping welcome lines move faster and leaving human helpers available for directions and questions.
Lin, a new student who arrived with a large bag, described the relief of watching an X30 take the load without wobbling:
It is really convenient. I cannot even imagine how exhausting carrying luggage would be without help from the robot. Zhejiang University has truly gone to great lengths to help us new students.
Zhejiang University's aim was to make the welcome smoother and set the tone for the first week. For parents, the machines added a lighter moment to a tiring morning. For students, they offered an early look at how robotics could support mobility, logistics and interaction between people and machines.
Engineering students could see design choices that they might later study, from joint motors to the shape of a robot's feet. Students in other subjects encountered questions about service design, ethics and how people respond to machines working nearby.
University research reaches campus paths and an ancient pagoda
DEEP Robotics grew out of Zhejiang University's research ecosystem. Its founder, Zhu Qiuguo, is an associate professor connected to the university's research community. The company illustrates how academic work on motion control and intelligent sensing can become products used outside a laboratory.
The control principles that keep a Lite3 upright during a spin also help an X30 climb a curb with a box. Campus deployments give engineers opportunities to observe real use, record data and refine designs in crowded, unpredictable spaces rather than only on test tracks.
China's universities are also taking robotic dogs into inspection and mapping work. In Shanxi province, a robot built by Lenovo worked with Tsinghua University's School of Architecture to scan the Wooden Pagoda of Yingxian County.
The robot collected images and depth measurements for models with high precision while keeping contact with the fragile ancient structure to a minimum. The project combined several types of sensing with artificial intelligence to create digital twins for future preservation work.
A digital twin is a detailed digital representation of a physical object or place. In the pagoda project, the measurements supported a model that could help people study the building and plan its care. Stable movement and rich sensing linked that preservation task to the very different work of transporting luggage on campus.
Other campuses introduce digital and physical helpers
Xi'an Jiaotong University introduced Jiao Xiaoxin, a chatbot powered by artificial intelligence, through its AI innovation platform Jiao Xiaozhi. The service combined a knowledge base, systems for handling workflows and large language models to answer common questions, provide navigation and suggest resources for incoming students.
Large language models are AI systems that process and generate language. In this service, they worked with university information and task systems to provide a digital front desk during the rush of the first week.
Xi'an Jiaotong University also gave its technology rollout a physical presence through Xun Xiao, a humanoid robot developed by its robotics institute. Xun Xiao greeted students at campus gates, answered questions about network access at information desks and walked people to particular service counters.
The robot appeared at the 2025 World Humanoid Robot Games in Beijing, where it demonstrated agile interactions across different settings. Its campus work involved short conversations and small tasks, giving students experience of a robot helping in situations that were less tightly scripted.
Northwestern Polytechnical University pursued a different form of assistance with a robotic guide dog that operated entirely offline. The machine guided users through elevators, stairs and street crossings without an internet connection.
The team used embodied AI, meaning intelligence inside a moving machine that senses its surroundings and makes decisions as it acts. It combined model compression, which reduces the computing demands of an AI model, with accelerated inference, which speeds up the process of producing a response. Together, those methods allowed large models to run on an onboard computer using little power.
For people who need consistent assistance, offline operation could support privacy and reliability where network coverage is weak. The guide dog project also showed that university robotics work extends beyond greetings and luggage to tasks involving everyday access and independence.
Zhejiang's robots are also chasing speed
Zhejiang University researchers have pursued performance far beyond the walking pace appropriate for a crowded arrival day. In May 2025, a university team announced that its White Rhino quadruped completed a 100 meter dash in 16.33 seconds.
Guinness World Records recognized that result as the fastest official time for a robot with four legs at the time of the announcement. The project used a forward design approach and reinforcement learning to coordinate fast leg movements and balance in real time.
Reinforcement learning trains a system through repeated attempts and feedback about its performance. For a running robot, the aim is to learn movements that produce speed while keeping the machine upright. The White Rhino group also said its robot could carry loads of up to 100 kilograms, connecting its speed research with possible work on difficult terrain.
Another Zhejiang University connection led to Black Panther 2.0, a sprint robot from Mirror Me. The Hangzhou startup was founded by university faculty and graduates. Researchers reported that the robot ran 100 meters in under 10 seconds during tests and a broadcast, a time faster than many human sprinters. White Rhino's 16.33 seconds was the Guinness recognized result; Black Panther 2.0's reported time came from its tests and broadcast.
The Black Panther team took inspiration from animal joints and paws. Springs at the knees absorbed shocks. Carbon fiber shins increased stiffness with only a small increase in weight, while running shoes shaped after cheetah claws improved grip.
The team also referred to the Huygens coupled pendulum principle, in which connected swinging systems can synchronize their motion, as a way to coordinate the limbs into a unified gait. Machine learning then adjusted foot timing as the robot ran.
Wang Hongtao, a Zhejiang University professor and head of a related institute, described the development pace in a briefing before the Beijing broadcast:
Through the integration of software and components, we created a prototype within a mere three months.
Jin Yongbin, a Zhejiang University researcher involved in the Mirror Me work, explained the challenge of maintaining movement step by step:
Animals have experience from long term learning, but our limbed robots need to relearn with each step.
The developments leading to the September welcome
The campus welcome sat alongside several robotics developments described during 2025. The sequence includes a recognized running record, a humanoid appearance in Beijing and the use of machines to assist incoming students.
- May 2025: Zhejiang University's White Rhino team announced a 100 meter time of 16.33 seconds, recognized by Guinness World Records at the time.
- 2025: Xun Xiao appeared at the World Humanoid Robot Games in Beijing, demonstrating interactions across different settings.
- By September 7, 2025: Zhejiang University's Zijingang campus had used Lite3, X30 and Lynx M20 robots to welcome students and help with luggage.
The exact date of Zhejiang University's welcome event was not given. The demonstrations nevertheless placed everyday campus assistance alongside more demanding research into speed, carrying capacity and independent navigation.
China is investing heavily in robotics to catch up with competitors and set the pace in some areas. Industrial robots already move parts in electric vehicle factories, humanoid platforms are improving their dancing and dexterity, and military robot dogs have appeared in tactical test videos. Campus helpers represent a visible, approachable part of that wider activity.
Useful assistance still needs supervision
Robotic dogs can reduce the physical strain of arrival day, lessen the need to move carts on stairs and free volunteers to answer questions. Possible tasks also include carrying first aid supplies and providing directions through voice systems or screens.
Predictable movement matters in crowds. A robot moving along a clear route can be easier to anticipate and avoid than a person changing direction while carrying two suitcases. For practical transport work, slow and steady movement is more useful than a display of speed or acrobatics.
Human supervisors need to remain nearby in busy areas. Clear safety zones give people room when a robot stops or pivots, and charging or battery swaps should happen away from queues. These arrangements help determine whether a machine is useful assistance or another obstacle during registration.
Cybersecurity is another part of operating a mobile machine with cameras and network access. In 2025, Field Effect researchers reported a hidden remote access path in some Unitree Go1 robots used by universities and laboratories. When the robots were online, the path connected to a tunnel service.
A tunnel service creates a route for remote connections to a device. With the right credentials, an outside party could have viewed camera feeds or issued commands through the reported access path. The manufacturer later disabled the service.
Campuses and vendors can apply practical safeguards when preparing robots for events:
- Keep firmware and software current, and test updates before deployment.
- Place robots on isolated wireless or wired networks through network segmentation.
- Provide manual control overrides and clearly accessible emergency stop buttons.
- Audit remote access services and camera streams for security problems.
- Limit where robots collect video and set clear privacy policies.
Network segmentation means separating devices into different parts of a network so access can be controlled more closely. Together with updates, audits and human overrides, it gives operators a more organized way to manage machines working among students and families.
From a welcome event to practical campus trials
Zhejiang University's demonstration linked classroom ideas with problems that occur on ordinary campus paths. Carrying a bag over uneven ground requires sensing, control and decisions about movement, all while people and other objects change position nearby.
Universities could build on such events through supervised trials with clearly defined tasks. Robots carrying packages could assist with library transfers or laboratory sample deliveries. Machines similar to Lynx M20 could inspect sidewalks and ramps for maintenance teams, while humanoid greeters such as Xun Xiao could help direct registration queues.
Each proposed use would give a robot a particular job and keep a human available to intervene. The campus would remain both a place where students learn engineering and a setting where machines encounter the less orderly conditions of daily life.
The welcome at Zijingang captured those two roles. Robots entertained families, carried weight and left an impression on thousands of young people, while demonstrating how university research can become practical assistance outside the laboratory.
Highlights
- Zhejiang University's Zijingang campus used three DEEP Robotics models to welcome new students.
- Lite3 danced and served drinks; X30 carried about 85 kilograms of luggage; Lynx M20 combined wheels and legs.
- Multiple sensors, motion control software and strong joints helped the robots handle crowds, stairs and uneven ground.
- DEEP Robotics was founded by Zhu Qiuguo, an associate professor connected to Zhejiang University's research community.
- Other university projects included Xi'an Jiaotong University's chatbot and humanoid greeter, and an offline robotic guide dog from Northwestern Polytechnical University.
- White Rhino recorded a Guinness recognized 100 meter time of 16.33 seconds; Black Panther 2.0 was reported to run the distance in under 10 seconds during tests and a broadcast.
- Supervision, emergency stops, controlled network access and privacy rules remain practical requirements for campus robot use.