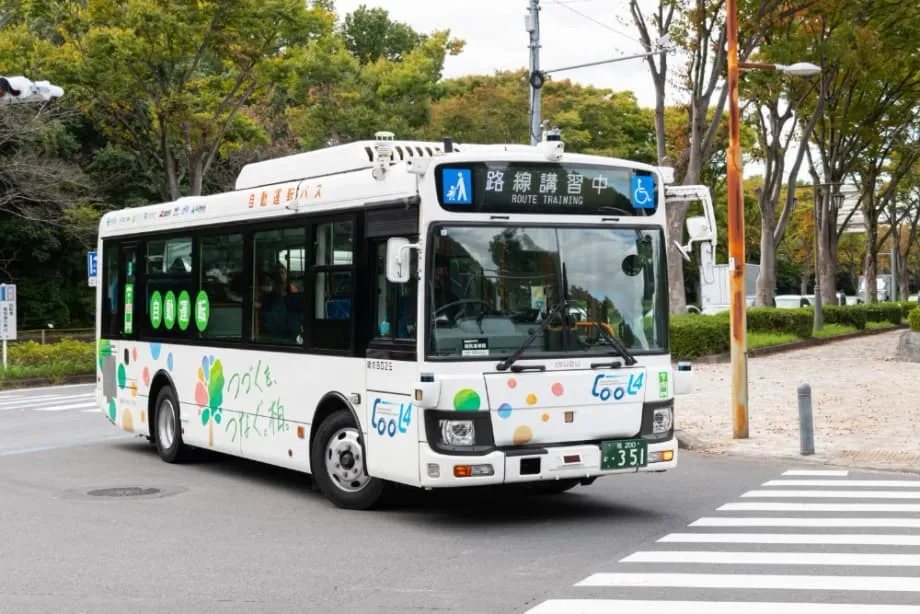
A 2.6 Kilometer Route Moves Toward Driverless Operation
A University of Tokyo research team began testing a Level 4 autonomous bus on public roads in the Tokyo metropolitan area on Tuesday, advancing a project that has operated with a lower level of automation since late 2019. The trial connects Kashiwanoha-campus station on the Tsukuba Express with the university's Kashiwa campus along a route measuring approximately 2.6 kilometers.
Contents
- A 2.6 Kilometer Route Moves Toward Driverless Operation
- What Level 4 Changes for the Bus
- How the Kashiwa Project Developed
- From a 17 Passenger Bus to a Larger Vehicle
- How the Bus Follows Its Route
- Remote Management Through Dispatcher
- Why Japan Is Pursuing Autonomous Transport
- The Organizations Behind the Trial
- Research on How Vehicles Communicate With Pedestrians
- Connecting Visual Signals to Driving Systems
- MiCa Shuttles and Other Deployment Plans
- What to Know
The route includes 2.3 kilometers of public roads and 0.3 kilometers on campus. The project is described as the first trial of a Level 4 autonomous bus on public roads in the Tokyo metropolitan area. Its location is Kashiwa, where university researchers, transport operators, local government and private companies have spent years studying how automated buses could become part of everyday public transport.
Level 4 means that a vehicle performs every driving task and handles difficulties within a defined operating area or set of conditions, without requiring human intervention. The earlier Level 2 system could control steering, acceleration and braking, but a human still had to supervise the journey.
Yoshihiro Suda, a professor at the University of Tokyo's Institute of Industrial Science and chair of the Kashiwa ITS Promotion Committee, explained why the change matters for public transport:
The transition from Level 2 to Level 4 autonomy represents a fundamental shift in how we approach transportation. At Level 4, the vehicle can handle all aspects of driving within its designated operational domain, including responding to unexpected situations. This creates new possibilities for public transportation that doesn't rely on human drivers, addressing Japan's critical driver shortage.
Japan's aging population, declining birthrate and shortage of drivers form the practical backdrop to the experiment. Rail and bus services have contracted in outlying areas, making it harder for residents to travel. The Kashiwa project is examining how autonomous buses might support a safe, comfortable and convenient service while researchers assess road performance, safety and daily operating requirements.
What Level 4 Changes for the Bus
The Kashiwa ITS Promotion Council describes automation through five levels, each assigning more of the driving work to the vehicle. The central difference is who must respond when the system encounters a difficult situation.
Level 1 covers assistance with either movement along the road, such as acceleration and braking, or movement across it, such as steering, within a limited area. Adaptive cruise control is an example of assistance with speed and distance. Level 2 combines both kinds of control, allowing the system to steer and manage acceleration and braking while a human supervises.
Level 3 performs all driving tasks within a restricted operating domain, but asks a person to intervene when difficulties arise. Level 4 performs those tasks and handles difficulties itself within that domain. Level 5 carries out all driving tasks without those limitations.
An operational domain is the area or set of conditions in which an automated system is designed to work. For the Kashiwa trial, the defined route is central to the project. Level 4 therefore brings independence from human driving within specified limits, while Level 5 represents complete automation without such limits.
The move from Level 2 to Level 4 changes more than how the steering wheel or brakes are controlled. It places responsibility for responding to driving difficulties on the automated system within its operating domain. That is why the project combines vehicle technology with remote monitoring, emergency response arrangements and continued evaluation of safety on the road.
How the Kashiwa Project Developed
The Kashiwa ITS Promotion Council was established in December 2009 as a forum for cooperation between the University of Tokyo, administrative bodies, private companies, various organizations and individuals. Its purpose includes promoting research and development and helping bring those activities into commercial and practical use.
The council began a demonstration of commercial operation using automated buses on November 1, 2019. The initial Level 2 phase continued until March 2020, using the route between Kashiwanoha Campus Station and the university's Kashiwa campus. Unlike many earlier autonomous driving trials conducted over short periods, this project was designed to examine operation across five months.
The main stages and related developments described in the project are:
- December 2009: The Kashiwa ITS Promotion Council was established.
- November 1, 2019: Automated bus demonstrations began on the 2.6 kilometer route.
- November 2019 to March 2020: The first Level 2 trial phase examined practical operation over five months.
- January 2021: A larger bus based on the Isuzu Elgamio entered the demonstrations.
- April 2023: Japan began allowing Level 4 vehicles to operate without drivers on public roads under specified conditions.
- Tuesday, as described in the January 14, 2026 account: The University of Tokyo research team began the Level 4 public road trial.
The demonstrations have examined practical routes, operating methods, inspections and maintenance over an extended period. The council has also connected its work with the development of new automated bus vehicles and the urban development of Kashiwanoha.
From a 17 Passenger Bus to a Larger Vehicle
The first trial used a commercial bus based on the Hino Motors Liesse, with capacity for 17 passengers. Advanced Smart Mobility Co., Ltd. developed its autonomous driving system, and TOBU BUS EAST CO., LTD. operated the vehicle.
The five months of testing were intended to reveal the practical demands of keeping an autonomous bus running over time. Researchers needed to understand the operating arrangements, inspections and maintenance required for a service following a real route, rather than a brief demonstration.
In January 2021, the project introduced a vehicle based on the Isuzu Elgamio. It had capacity for 56 passengers, including 28 seated passengers. COVID-19 precautions limited the actual passenger capacity to 15 during that phase.
The larger vehicle's stated capacity was 39 passengers greater than the earlier bus's 17 passenger capacity. The temporary limit of 15 passengers, however, meant that the demonstration operated below even the smaller vehicle's stated capacity while those precautions applied.
Advanced Mobility Corporation used knowledge gained from demonstrations beginning in 2019 to improve the automated driving system. The changes included greater sensing capability, a larger vehicle and better ride comfort during acceleration and deceleration.
The updated bus continued at Level 2 during that phase, with a planned transition to Level 4 based on ongoing evaluations. The latest trial follows that progression, linking the earlier work on vehicle control and passenger comfort with the broader task of autonomous operation.
How the Bus Follows Its Route
The autonomous bus combines lane keeping control, satellite positioning, magnetic marker sensors and automated accelerator and brake control. Each contributes to a different part of the journey, from locating the bus to maintaining its position and controlling speed.
GNSS, the satellite positioning technology that includes GPS, helps identify the vehicle's location. Magnetic marker sensors provide precise localization along the route. Lane keeping control helps the bus maintain its position on the road, while speed maintenance control manages acceleration and braking.
The bus also has an SRA function described as distance control at all speeds. This adds control of the distance between the bus and traffic ahead to the vehicle's other driving functions.
Cameras recognize traffic light colors so the vehicle can respond appropriately at signals. Automated bus stop arrival and departure controls address another routine part of a bus journey: approaching a stop and then leaving it.
The improvements introduced during the project's development also targeted ride comfort. Smoother acceleration and deceleration matter to passengers as well as vehicle operation, particularly as the project moves from a smaller bus to a vehicle with greater capacity.
Remote Management Through Dispatcher
BOLDLY Corporation's Dispatcher platform connects the Level 4 trial bus to an automated vehicle operation management system. Its functions cover remote status monitoring, driving instructions, emergency response and decisions about whether driving can proceed.
Dispatcher also records driving activity and errors. Those records sit alongside its monitoring functions, giving the project a way to follow vehicle operation and document problems that occur during a journey.
The platform's remote functions include driving recording, error recording, status monitoring, driving instructions, emergency response and decisions described as determining whether travel is advisable or unavoidable. Together, these functions form part of the project's safety and operational management arrangements.
The bus maintains communication with a remote control center that can intervene when necessary. Vehicle automation and remote management therefore work together: the bus handles driving within its operating domain, while the center monitors its condition and supports operational decisions and emergency response.
The project's emphasis on remote management reflects the scope of running a public transport service. Steering and braking are only part of the job. Operators also need to know whether a vehicle is available to run, what has happened during its journey and how to respond when a problem occurs.
Why Japan Is Pursuing Autonomous Transport
Japan's demographic changes and driver shortage have put pressure on transport services. An aging population and declining birthrate are accompanied by contraction of rail and bus services in outlying areas, creating mobility difficulties for residents.
Municipalities are increasingly looking to autonomous driving technology as a way to address those difficulties. Since April 2023, Japan has allowed Level 4 autonomous vehicles to operate without drivers on public roads under specified conditions, providing a regulatory framework for wider implementation.
Yuki Saji, president and CEO of BOLDLY Inc., described the transport pressures behind that interest:
In light of demographic shifts such as an aging population, a declining birthrate and a shortage of drivers, Japan's transportation infrastructure is facing challenges as rail and bus services contract in outlying areas. To address these mobility challenges, municipalities in Japan are increasingly looking to autonomous driving technologies as a solution.
The Kashiwa trial addresses that goal through practical testing. Researchers are evaluating road performance and safety with Level 4 autonomy or higher in mind. The project also calls for further autonomous bus development and continued trial operations with new vehicles introduced after evaluation.
Kashiwanoha neighborhood development is part of the same effort. The aim is to create a service that residents can use safely, comfortably and conveniently, connecting transport research with the development of the surrounding community.
The Organizations Behind the Trial
The Kashiwa project brings together university researchers, local government, a bus operator, technology companies and organizations involved in urban planning, insurance and property development. The Kashiwa ITS Promotion Council provides a forum for coordinating those contributions.
University participants include the University of Tokyo Mobility Innovation Collaborative Research Organization, the Institute of Industrial Science and the Graduate School of Frontier Sciences. The City of Kashiwa participates alongside Advanced Smart Mobility Co., Ltd. and TOBU BUS EAST CO., LTD.
Other organizations listed in the automated bus demonstrations are Mitsui Fudosan Co., Ltd., SB Drive Corp., Urban Design Center Kashiwanoha (UDCK), Pacific Consultants Co., Ltd., Sompo Japan Nipponkoa Insurance Inc. and Mitsubishi Auto Leasing Corporation.
The collaboration combines transport technology with the practical demands of introducing a service into an urban environment. The project's work covers operating methods, inspections and maintenance while also taking account of neighborhood development.
The initiative is associated with the Kashiwanoha Smart City Consortium, selected by Japan's Ministry of Land, Infrastructure, Transport and Tourism as a smart city project and an advanced model project. The stated approach connects advanced transport systems with sustainable urban development.
Research on How Vehicles Communicate With Pedestrians
University of Tokyo research extends beyond the mechanics of driving. A study led by Professor Takeo Igarashi of the Graduate School of Information Science and Technology explored whether robotic eyes fitted to a self-driving vehicle could help pedestrians decide when to cross.
The eyes could look toward pedestrians to signal that their presence had been registered, or look away when they were not being detected. The study found that these visual cues affected pedestrian behavior, helping participants make safer and more efficient crossing decisions.
Igarashi explained the need to investigate communication between automated vehicles and the people around them:
There is not enough investigation into the interaction between self-driving cars and the people around them such as pedestrians. So we need more investigation and effort into such interaction to bring safety and assurance to society regarding self-driving cars.
Male participants made fewer dangerous crossing decisions when the vehicle's eyes looked at them. Female participants made fewer inefficient decisions, meaning fewer occasions when they chose not to cross despite it being safe, under the same conditions.
The experiment produced smoother or safer crossing decisions for everyone. The researchers acknowledged that the study involved a small number of participants and just one scenario. They described the results as promising and said robotic eyes deserved serious consideration if they could contribute to safety and reduce traffic accidents.
Connecting Visual Signals to Driving Systems
Igarashi's team would like to develop automatic control of the robotic eyes linked to the vehicle's self-driving artificial intelligence. The eyes in the study were controlled manually; connecting them to the driving system could allow their behavior to adapt to different situations.
The research examines a practical concern in the move from manual driving to automated driving: how a vehicle communicates its awareness to a pedestrian. The proposed automatic system would connect that communication more directly with what the vehicle's driving technology detects.
The university's bus project and pedestrian research address different parts of autonomous transport. The bus demonstrations examine vehicle operation, remote management, maintenance and safety along a defined route. The robotic eyes study examines the interaction between a vehicle and someone deciding whether to cross in front of it.
Both strands place attention on everyday encounters rather than driving mechanics alone. For the bus project, that includes stopping, departing and responding to traffic signals. For the pedestrian experiment, it includes giving people a visible cue about whether the vehicle has registered their presence.
MiCa Shuttles and Other Deployment Plans
BOLDLY's work also includes MiCa, a Level 4 autonomous shuttle developed by Estonia-based Auve Tech. BOLDLY was described as the first company in the world to purchase MiCa, with plans to begin testing it on Japanese roads in 2023.
The preparations included arranging demonstration runs, obtaining permits from relevant government agencies and laying the groundwork for public road testing beginning in summer 2023. The Japanese version was adapted with devices and cameras compatible with Dispatcher.
MiCa's Japanese version also placed its doors on the left to accommodate Japanese roads. The Estonian version had its doors on the right. This change accompanied the adaptations for BOLDLY's operation management platform.
The Town of Sakai in Ibaraki Prefecture, described as the first municipality to implement BOLDLY's autonomous driving systems in 2020, signed an agreement to purchase MiCa shuttles. Its stated plan was to have them operating on local roads within 2023. BOLDLY also aimed to introduce approximately 10 MiCa vehicles in Japan during the fiscal year referenced in those plans.
Those schedules were plans associated with the 2023 preparations; their completion status was not given in the January 14, 2026 account. For Kashiwa, the stated next steps are to evaluate the trial, develop new autonomous bus vehicles and continue operations with new vehicles based on the results.
The projects are intended to provide useful information about operating methods, maintenance requirements and passenger acceptance. In Kashiwa, the immediate task remains evaluating road performance and safety while building toward a transport service integrated with the surrounding neighborhood.
What to Know
- A University of Tokyo team began a Level 4 autonomous bus trial on public roads in the Tokyo metropolitan area on Tuesday.
- The Kashiwa route measures approximately 2.6 kilometers, including 2.3 kilometers of public roads and 0.3 kilometers on campus.
- Level 4 systems perform all driving tasks and handle difficulties within a defined operating domain without human intervention.
- Level 2 demonstrations began on November 1, 2019; a larger Isuzu Elgamio bus entered the project in January 2021.
- The bus combines satellite positioning, magnetic marker sensors, lane keeping, speed control, traffic light recognition and automated bus stop functions.
- BOLDLY's Dispatcher platform supports remote monitoring, driving instructions, emergency response and operational records.
- Japan has permitted Level 4 operation without drivers on public roads under specified conditions since April 2023.
- The project aims to address transport pressures linked to population changes and driver shortages while evaluating safety and practical operation.
- University research also examines how robotic eyes on autonomous vehicles can help pedestrians make crossing decisions.
- Further vehicle development and continued trials are planned based on evaluations of the Kashiwa project.